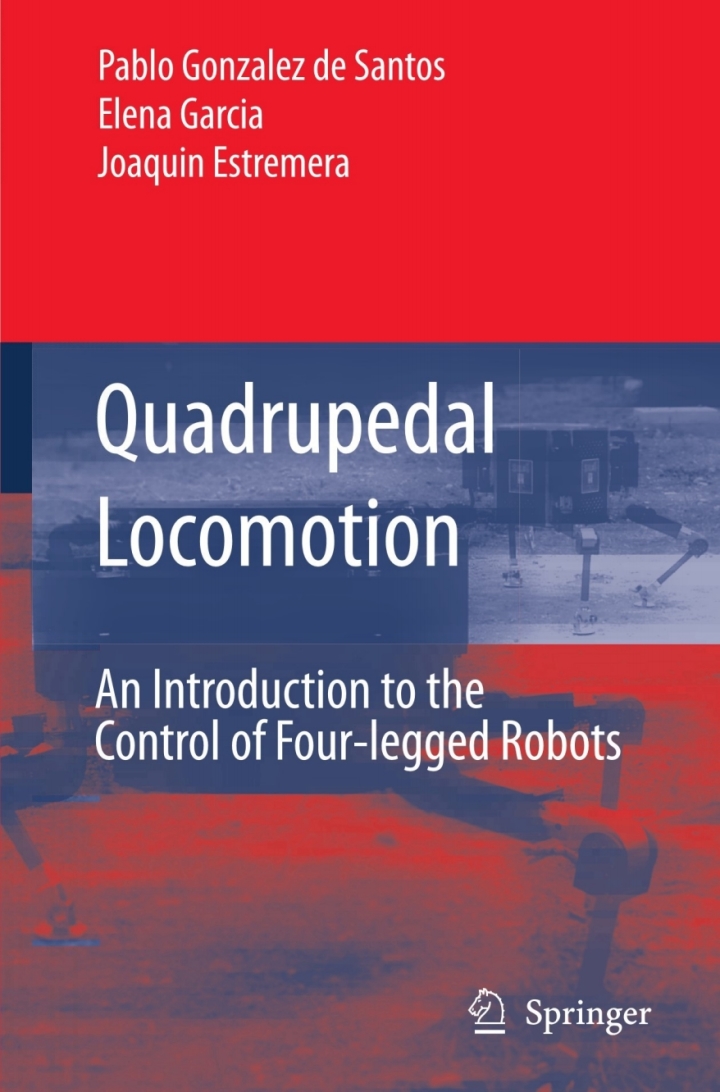
Quadrupedal Locomotion: An Introduction to the Control of Four-legged Robots
In stock
Quadrupedal Locomotion: An Introduction to the Control of Four-legged Robots
$28.00
Legged robots have proven to be a promising locomotion system, capable of performing tasks that conventional vehicles cannot perform. Even more exc- ing is the fact that this is a rapidly developing - eld of study for researchers from a variety of disciplines. Over the past three decades, legged locomotion technology has been developed all over the world, resulting in the invention of many important new machines and methods. However, only a few books have been published on the subject of multi-legged robots.
The main objective of this book was to explore some of the major issues that the authors have been analyzing over the past ten years. A second objective was to write a book that only encompasses quadruped locomotion, the rst specialized book on this topic. The book is divided into two parts: Walking Measurements and Algorithms, and Control Techniques. The rst part is devoted exclusively to the theoretical aspects of quadrupeds.
The rst chapter is an introduction to the historic development of multi-legged robots, highlighting their advantages and disadvantages, main features, and potential and actual applications, as well as discussing basic concepts and the trade-où between quadrupeds and hexapods. Finally, new and traditional stability measurements and gait g- eration algorithms for quadrupeds are explained.
The second part of the book deals with general design and control algorithms (kinematics and dynamics) and techniques aimed at improving the main features of robots, such as speed and ground detection, interfaces,etc.
Book Details
- Authors: Pablo González de Santos, Elena Garcia, Joaquin Estremera
- Publisher: Springer
- eBook ISBN: 9781846283079, 1846283078
- Print ISBN: 9781846283062, 184628306X
Product Details
You May Also Like
View all →
Advances in Computer Science and Information Technology: First International Conference on Computer Science and Information Technology, CCSIT 2011, Bangalore, India, January 2-4, 2011. Proceedings, Part I
Designing Democracy Re-education and the America Houses (19451961)- The American Information Centers and their Involvement in Democratic: Re-education in Western Germany and West Berlin from 1945 to 1961

Advances in Neuroergonomics and Cognitive Engineering: Proceedings of the AHFE 2016 International Conference on Neuroergonomics and Cognitive Engineering, July 27-31, 2016, Walt Disney World®, Florida, USA